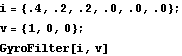GyroFilter
3D• GyroFilter[{Ixx, Iyy, Izz, Ixy, Iyz, Izx}, {x, y, z}] returns a new set of inertia properties that have zero inertia in the direction of {x, y, z}.
• The vector {x, y, z} must be a principal axis of the inertia properties, and the two principal moments not associated with {x, y, z} must be equal. • Inertia[GyroFilter[inertia, vector]] . vector always returns the zero vector, which shows that a body represented by the new inertia properties has no angular momentum if rotating about vector.
• GyroFilter is normally used to filter out components of the inertia tensor that are modeled as zero-torque spinning motion with GyroMoment.
• It is never necessary to use GyroFilter if the gyro body is attached to the rest of the model by a zero-torque constraint, like a revolute or cylindrical joint.
• Use Inertia->GyroFilter[inertia, vector] as an option for Body to eliminate the axial torques related to angular acceleration of the body, and then use the unfiltered inertia properties with GyroMoment to model the gyroscopic torques.
• The inertia properties may also be given as a full inertia matrix.
• See also: ParallelAxis, PrincipalAxes. Further Examples Load the Modeler3D package. Here GyroFilter is used to filter out the principal moment of inertia in the X direction.
Out[4]= | 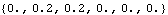 |
We can rotate the inertia properties to another reference frame and still use GyroFilter to remove the principal moment.
Out[6]= | 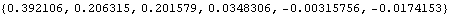 |
Out[7]= | 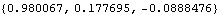 |
Out[8]= | 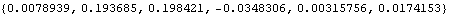 |
We can show that the result is still effectively the same--the principal moment of inertia has been reduced to zero. Note that the last principal axis is equal to our rotated vector v.
Out[9]= | 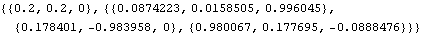 |
|